demo source-backed
Jev × LIBERO: robot decisions with local physics previews
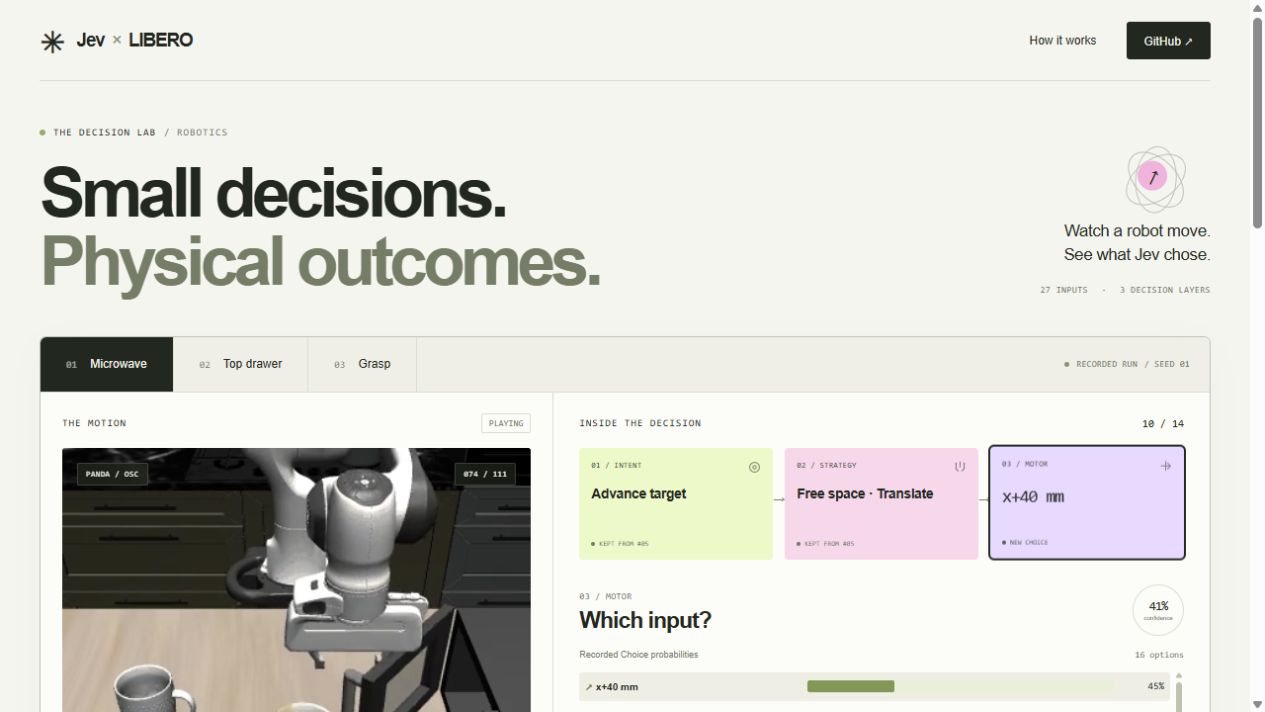
A configurable LIBERO robot-control experiment that combines Jev decisions with reversible physics previews. An interactive replay follows intent, motion family and control choices alongside saved trajectories.
Notes
The repository includes three seed-1 task records passing their LIBERO criteria: microwave closure in 14 decisions, drawer closure in 20, and soup-can placement in 40; the controller offers 27 control inputs.
source-backed — Public repository, docs or live artifact. About this label
Destinations
Verification levels
- HTTP availability
- Link reachable ·
Method: bounded HTTP request with redirects. HTTP 200 · HTTP response only. Checked destination ↗ · Last reachable - Browser demo scenario
- Not checked
- Build
- Not checked
- Live API test
- Not checked